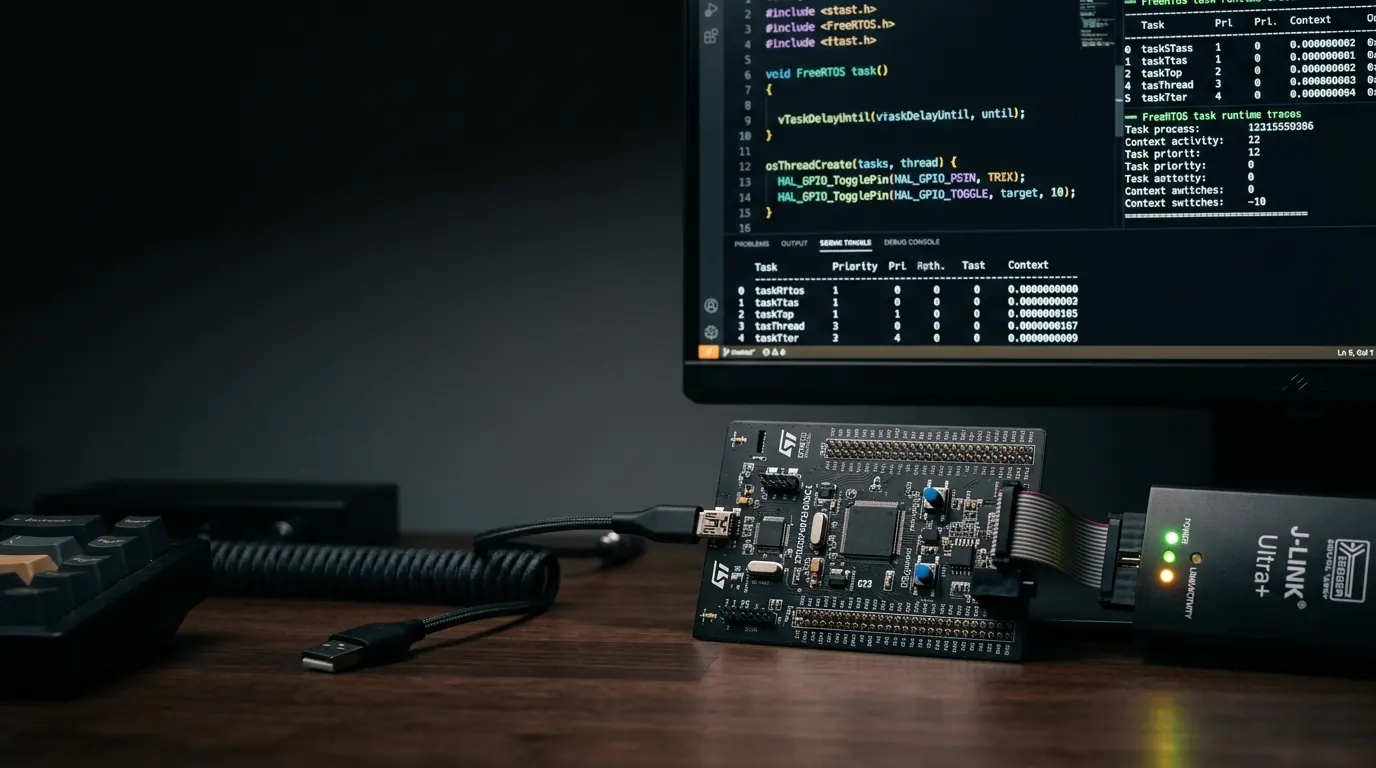
Firmware Development ServicesFirmware That Runs On Real Hardware
STM32, ESP32 and BLE MCUs, on FreeRTOS or bare metal, from part selection to delivery. Shenzhen, since 2016.
Service Overview
Production firmware for microcontroller-based products across STM32, ESP32/ESP32-S3, Nuvoton N76E003, Ambiq Apollo2, ATMEGA32U4 and 8051-family parts. FreeRTOS or bare metal as the product requires, with Keil/IAR/GCC multi-toolchain support.
XTELL is a firmware development company writing firmware for STM32, ESP32 and BLE MCU products, on FreeRTOS or bare metal, from part selection to delivery.
Who this firmware development service is for
• Hardware companies whose products carry a microcontroller and need complete firmware - from MCU selection and peripheral drivers to system integration - not a sample driver.
• Clients whose board is fixed but who lack a firmware team: hardware and BOM are frozen, and someone needs to take the firmware to delivery.
• Clients whose product must pass FCC or CE certification, where RF and power-related firmware decisions need to leave margin for certification early on.
• Clients for whom diagnosing devices is expensive, and who want a supplier that opens the firmware to find the fault rather than relaying the symptom.
Which microcontrollers we write firmware for
This page covers three MCU families: STM32, ESP32 and BLE MCUs, on FreeRTOS or bare metal. Delivered projects also include AVR: the microscope motorized stage runs on an ATMEGA32U4, and the smart finger servo control system is built on Arduino and AVR. When the MCU has not been chosen, selection is part of the service - chips are picked for the product's needs, not for whichever dev board the team knows best.
STM32 firmware development: FreeRTOS real-time scheduling and high-speed SD recording
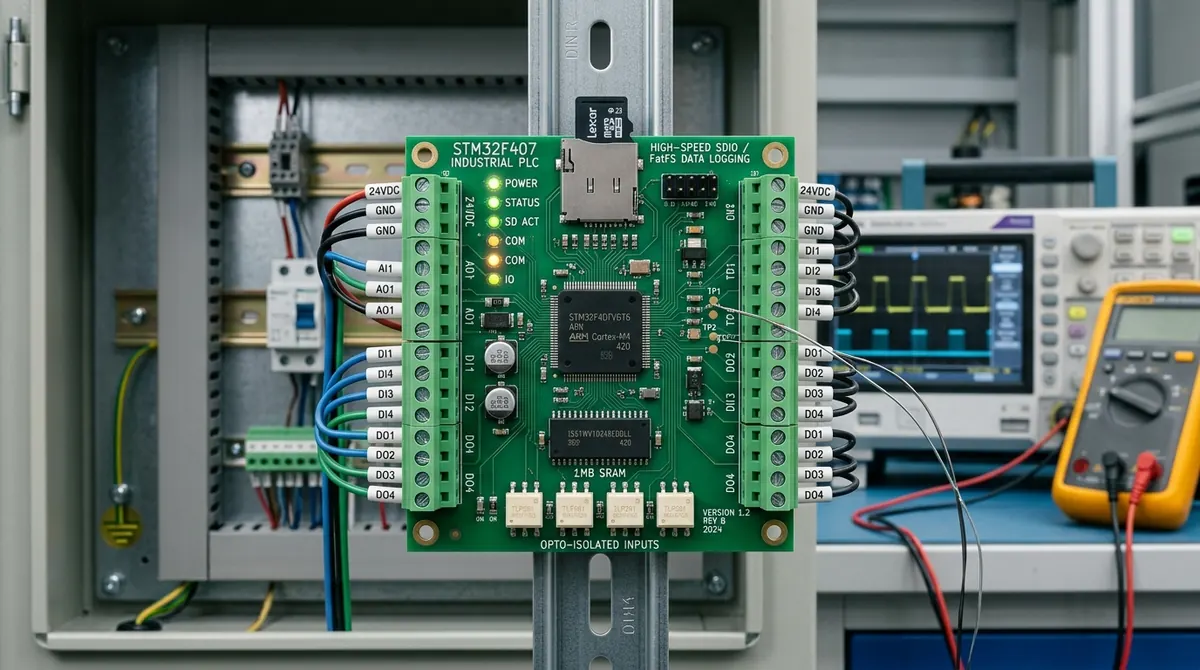
The STM32 PLC industrial control system is the representative STM32 project. It drives the hardware through the STM32F407 HAL library, uses FreeRTOS for multi-task real-time scheduling, records data to SD card at high speed through the FatFS file system over SDIO, expands runtime memory with external SRAM, and uses UART for industrial communication. On the STM32F407 three requirements had to hold at once: real-time scheduling without missed tasks, FatFS running long-term without failure, and SDIO recording at speed without dropping data. The difficulty in STM32 firmware development is never blinking an LED; it is keeping real-time behaviour, file system stability and fast peripherals from stepping on each other.
ESP32 firmware development: multi-sensor data fusion and reliable WiFi upload
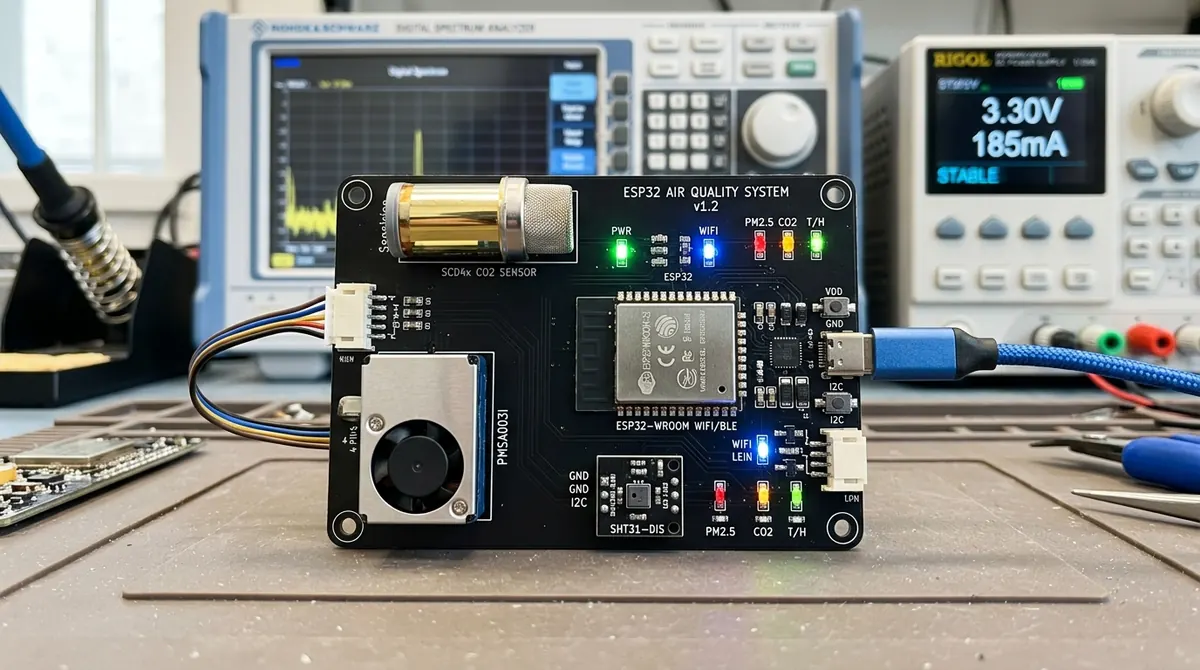
The ESP32 air quality collector is the representative ESP32 project. The ESP32 board drives several air quality sensors, fuses their readings, and uploads the result over WiFi for environmental monitoring. The difficulty is not reading one sensor but fusing several and keeping WiFi transfer reliable - those two concerns set the firmware architecture. Environmental monitors often run in the field for long periods, so the reliability of the link directly decides whether the data is complete.
BLE firmware development: battery life is set at the architecture stage
BLE MCU firmware is within this service. BLE devices are mostly battery powered, and sleep current, connection interval and advertising duty cycle fix the battery life at the firmware architecture stage, leaving little room to recover later. The core BLE trade-off is that frequent communication gives good responsiveness at a power cost, while longer intervals save power at the expense of experience. There is no general answer to this; it has to be calculated from the product definition.
For Bluetooth we work across Nordic nRF52 and nRF53, JL7018 and WCH CH58x/CH59x - from the premium end to cost-optimised domestic parts - and choose on requirements, not on which part the team happens to know best.
FreeRTOS or bare metal is decided by the product
FreeRTOS is not the default, and bare metal is not the backward choice. The STM32 PLC industrial control system runs data logging, industrial communication and business logic in parallel, so FreeRTOS multi-task scheduling is right for it. A product with few tasks and simple timing is more compact on bare metal with interrupts, and saves the scheduler overhead. The choice between an RTOS and bare metal is fixed at the architecture stage and written into the proposal, not left for later rework.
Motor control firmware: stepper micro-motion and coordinated servos
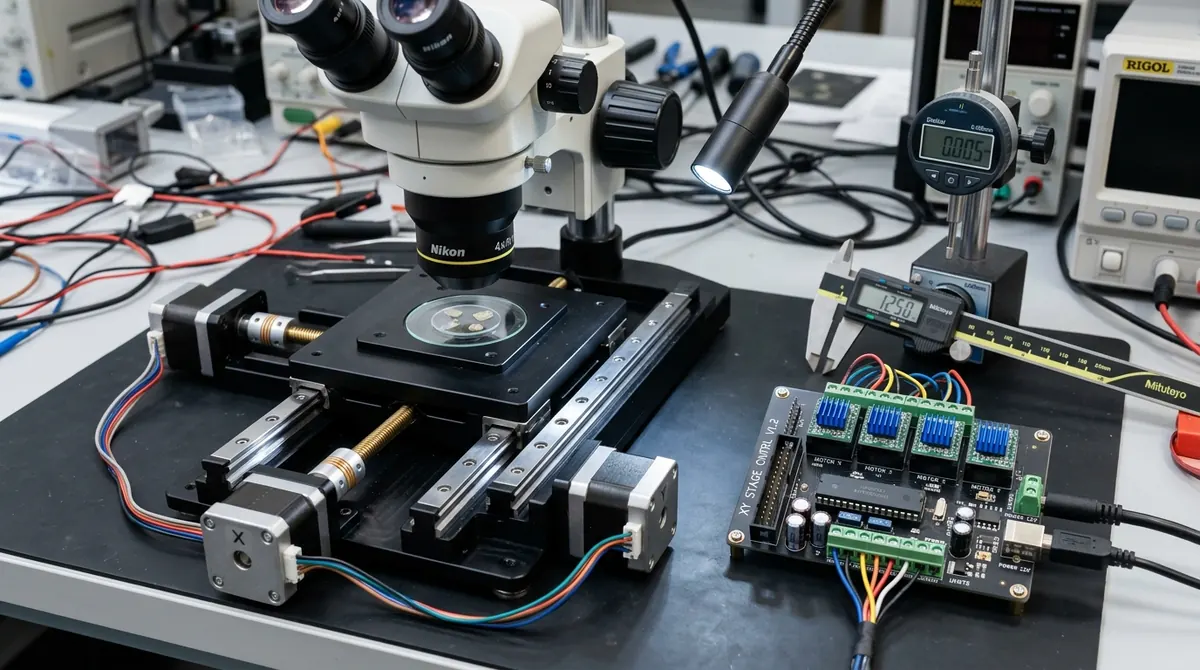
Motor control firmware is its own class of problem, and XTELL has delivered two such projects. The microscope motorized stage runs 3CNC firmware on an ATMEGA32U4, driving its motors through A4988 and HR4988E stepper drivers expanded via an Arduino CNC Shield, for high-precision micro-motion of a microscope stage; the micro-platform PCB was designed alongside, and the structure was done in FreeCAD with STEP output. The smart finger servo control system targets a bionic finger: an Arduino and AVR microcontroller controls the servos, servo.ino sets multiple servo angles, a USBASP board handles programming, and the main board integrates the drive circuitry. Multi-axis coordination and precise position feedback were the shared challenge.
Firmware runs on boards we design, so the debugging loop is short
Most XTELL firmware runs on boards we designed. When a peripheral misbehaves we can check the schematic, put a scope on the signal and change the next board revision, instead of emailing a hardware supplier and waiting. PCB design is done in KiCad and mechanical design in FreeCAD, so firmware engineers and hardware design close the loop inside one team.
Why hand firmware to a full-stack team
One team writes the firmware, the app and the backend. When a device misbehaves, a software-only supplier can only relay the symptom - the device didn't report. XTELL can open the firmware and see what the device actually sent and whether the server received it. Diagnosis needs no message-passing between two suppliers and integration needs no cross-company scheduling, which is one of the main reasons western B2B clients choose us.
Firmware work supporting FCC and CE certification
Clients' products routinely need certification, and XTELL supports the FCC, CE and related work. Certification has real consequences for firmware: RF parameters, operating modes and power behaviour must be configurable and reproducible at the firmware level, and we prepare the test firmware builds and documentation the lab needs. Certificates are issued by accredited test labs; we make sure the device behaves consistently on the test bench.
The firmware technology we commonly use
• MCUs: STM32 (such as the STM32F407), ESP32, BLE MCUs (Nordic nRF52/nRF53, JL7018, WCH CH58x/CH59x), AVR and Arduino (such as the ATMEGA32U4)
• Operating systems: FreeRTOS, bare metal
• Storage and memory: FatFS, SDIO, SD card logging, external SRAM
• Communication: UART industrial communication, WiFi data upload
• Motor and motion control: A4988 and HR4988E stepper drivers, multi-channel servo control, Arduino CNC Shield, 3CNC firmware
• Languages and tools: C, Arduino, USBASP programming
• Hardware tools: KiCad for PCB design, FreeCAD for mechanical design
How we work together and how delivery scope is agreed
1. Requirements review: share the MCU, the schematic if it exists, and the functional requirements, and we confirm feasibility.
2. Proposal and contract: scope, milestones and engagement model are written down here. Whether source code and design files are delivered, and under an open or closed model, is agreed item by item in the contract. Nothing on this page constitutes a blanket commitment.
3. Development and integration: firmware and hardware are verified together, with measured data in place of assumptions.
4. Delivery: scope follows the contract. Timeline and price depend on scope and are given after assessment; this page does not fix numbers.
ESP32-S3: the default choice for screens, USB and on-device inference
Within the Espressif family we select per product rather than per habit. The ESP32-S3 earns its place when the product has a colour screen, needs native USB, or runs on-device inference: its vector instructions, larger external PSRAM support and USB-OTG are what separate it from the original ESP32 and the cost-focused C3. For a plain sensor node that reads a value and publishes it, a cheaper part does the same job for less.
The engineering work on an S3 product concentrates in three places. PSRAM type and size have to come from a written memory budget before the interface is designed - quad versus octal decides whether a display tears under load. Display bandwidth is calculated from resolution, colour depth and frame rate before the panel is ordered, not discovered during bring-up. And battery life is budgeted from duty cycle - deep sleep current, the cost of associating and establishing a session, and the share of time the radio is actually transmitting - then corrected against measured current on real hardware.
About XTELL
XTELL (Shenzhen XTELL Future Technology) was founded in Shenzhen in 2016. Over the ten years since, it has delivered more than 100 projects, with clients predominantly western B2B companies. Its work covers every layer from circuit board to cloud: PCB design, FPGA, embedded firmware, Linux BSP, device interfaces, mobile apps, backends and IoT platforms.
Service Features
Technology Stack
Related Project Cases
STM32F407 Industrial PLC Controller
FreeRTOS multi-task scheduling on STM32F407 with FatFS over SDIO for high-speed data logging, external SRAM for runtime memory expansion and UART industrial communication.
ESP32 Air Quality Collector
ESP32-based sensor node fusing data from multiple air quality sensors with WiFi upload.
Arduino Servo Control System
Arduino and AVR multi-servo control with a dedicated USBASP programming board, a main control board and mechanical integration.
Microscope Motorized Stage
ATMEGA32U4 running 3CNC firmware with A4988 and HR4988E stepper drivers, micro platform PCB and STEP/FreeCAD structural design for high-precision micro-motion control.
What You Receive
Frequently Asked Questions
Do you deliver the firmware source code?
We work under both open and closed models. Whether source code is delivered, and how it is licensed, is agreed item by item in the contract. This page makes no blanket commitment; tell us your preferred model at the quoting stage.
Which platforms do you mainly write firmware for?
STM32 (representative project: the STM32F407 industrial control system), ESP32 (the air quality collector), AVR and Arduino (the ATMEGA32U4 micro-motion stage and the servo control system), and BLE MCUs (Nordic nRF52/nRF53, JL7018, WCH CH58x/CH59x). We work on FreeRTOS and on bare metal.
How do you choose between FreeRTOS and bare metal?
By the product. A system running data logging, communication and business logic in parallel uses FreeRTOS multi-task scheduling, as the STM32 PLC industrial control system does. A product with few tasks and simple timing is more compact on bare metal with interrupts. XTELL writes the choice into the proposal at the architecture stage rather than guessing later.
The board is already designed. Can you do only the firmware?
Yes. Send the schematic and existing constraints and we can take it on. If hardware issues turn up later, XTELL also does PCB design in KiCad and can produce a new revision, but whether that happens and whether it is in scope is agreed in the contract.
Can an Arduino-class platform handle a demanding product?
Yes, within limits. The microscope motorized stage uses an ATMEGA32U4 running 3CNC firmware with A4988 stepper drivers to achieve high-precision micro-motion, and it is a delivered project. AVR has a ceiling on processing and storage; when requirements exceed it we say so and recommend a different platform rather than forcing an unsuitable one.
Do you handle FCC and CE certification?
Certificates are issued by accredited test labs. XTELL handles the development work certification depends on: RF and power decisions at the firmware level, and the firmware builds and documentation testing needs. Clients' products routinely need FCC or CE, so this is a standard part of a project, not an extra.
Need Professional Services?
Contact us for customized solutions and quotes